 Control Techniques
 Estun Automation
 CODESYS
 Crevis
 Nexcom / Nexcobot
 Leroy-Somer
 Servo Systems
 AC Drive + Motor
 DC Drives
 Smart PLC
 Panel PC / IPC
 Remote I/O

Flying shear control
Double-head flying shear synchronized to line speed on a 1 ms EtherCAT cycle.
View solution
 CODESYS System Partner
A smart controller is a SoftPLC that runs the CODESYS Control runtime on an industrial PC. With this architecture ONX Control builds machine logic, the operator interface, servo axes, EtherCAT communication and data collection on one device and in one project.
PLC, HMI, motion, CNC, alarms, recipes, data collection and service layers in the same CODESYS project.
The same engineering on a fanless IPC, panel PC, edge controller or compact machine controller.
Field devices and plant systems from one place over EtherCAT, Modbus TCP/RTU, OPC UA and CANopen.
Beyond a standard PLC with SoftMotion, servo axes, cams, electronic gearing and CNC interpolation.
Controller platforms
The same CODESYS backbone takes different roles on different hardware. The right choice depends on control load, motion requirements, data traffic and the maintenance scenario.
 Fanless IPC + CODESYS
Low-maintenance controllers for 24/7 operation, mounted in the cabinet or on the machine. SoftPLC, communication, data collection and remote service on one platform.
 HMI + PLC in one unit
Combines the operator interface and the control layer in one unit; wiring, commissioning and maintenance get simpler on compact machines.
 SoftMotion + EtherCAT
A motion control backbone for servo axis synchronization, pick & place, flying shears, rotary knives, interpolation and multi-axis packaging machines.
Architecture layers
At ONX Control a CODESYS-based controller is more than a PLC cycle: motion control, visualization, fieldbus communication and service processes are designed in one architecture.
ONX Control does more than supply hardware; it develops its own EtherCAT communication stack at kernel level. A hardware-independent, deterministic control architecture based on real-time Linux that reduces external dependency.

ONX software libraries
Power, S-curve positioning, jog, homing, electronic gearing and master-based profiles for EtherCAT CiA402 servo axes. Field-tested with Estun and Control Techniques drives.
ExploreTurns G-code into smooth 5-axis motion with spline merging, corner smoothing and jerk-limited velocity planning; with a web-based HMI.
ExploreNeither library needs a SoftMotion axis licence.
From the field
Double-head flying shear synchronized to line speed on a 1 ms EtherCAT cycle.
View solution
Fast multi-axis bottle filling machine with CODESYS SoftMotion cam profiles.
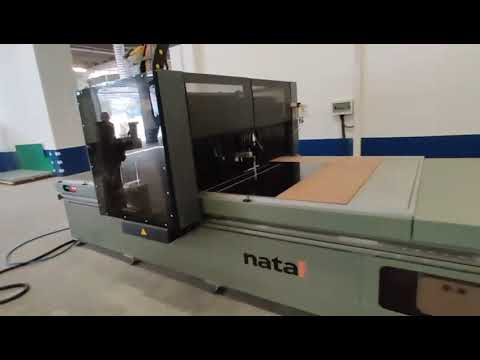
3-axis router with CODESYS SoftMotion CNC; modernizing legacy machines with EtherCAT.
View solution
Tension control with diameter-based torque on winder / unwinder applications.
View solutionEngineering note
Choosing a controller by core count or memory alone is a common mistake. The right choice weighs real-time task structure, motion load, communication density, data collection, HMI behaviour, remote service and long-term maintenance together.
A controller in which the CODESYS Control runtime runs on an industrial PC or panel PC. PLC logic, HMI, motion control, fieldbus communication and data collection run on the same hardware and in the same CODESYS project instead of separate devices.
Programming uses the same IEC 61131-3 languages. The difference is that a SoftPLC is not tied to specific hardware: the same software can move to PCs of different power, uses the PC's processor, memory and network resources, and HMI and data tasks run on the same device.
EtherCAT, Modbus TCP/RTU, OPC UA and CANopen are used on the platforms on this page. On the plant side, SQL, MQTT and ERP / MES links can be set up.
Axis control can be done with CODESYS SoftMotion. ONX Control's own libraries, X Motion Library (EtherCAT CiA402 axis control) and X CNC Library (from G-code to axis motion), do not need a SoftMotion axis licence; a CODESYS Control runtime licence and the ONX lock code are enough.
The choice should depend on control load, motion requirements, data traffic and the maintenance scenario rather than screen size. Once I/O density, the HMI's role, the number of axes and data flow are defined, the decision is made between an edge controller, a panel-based controller or a motion / CNC platform.
An EtherCAT communication stack based on real-time Linux, developed by ONX Control within TÜBİTAK 1501 Industrial R&D project no. 3250444. It aims at a hardware-independent, deterministic control architecture; the technical report can be downloaded from this page.
Share your I/O count, axes, HMI needs and communication infrastructure; we will come back with a platform proposal and an architecture draft.
By submitting this form, you confirm that you have read the Privacy Notice (KVKK) on how we process your personal data to respond to your request.